
Wall-climbing robot
A magnetic-adhesion robot for surface inspection
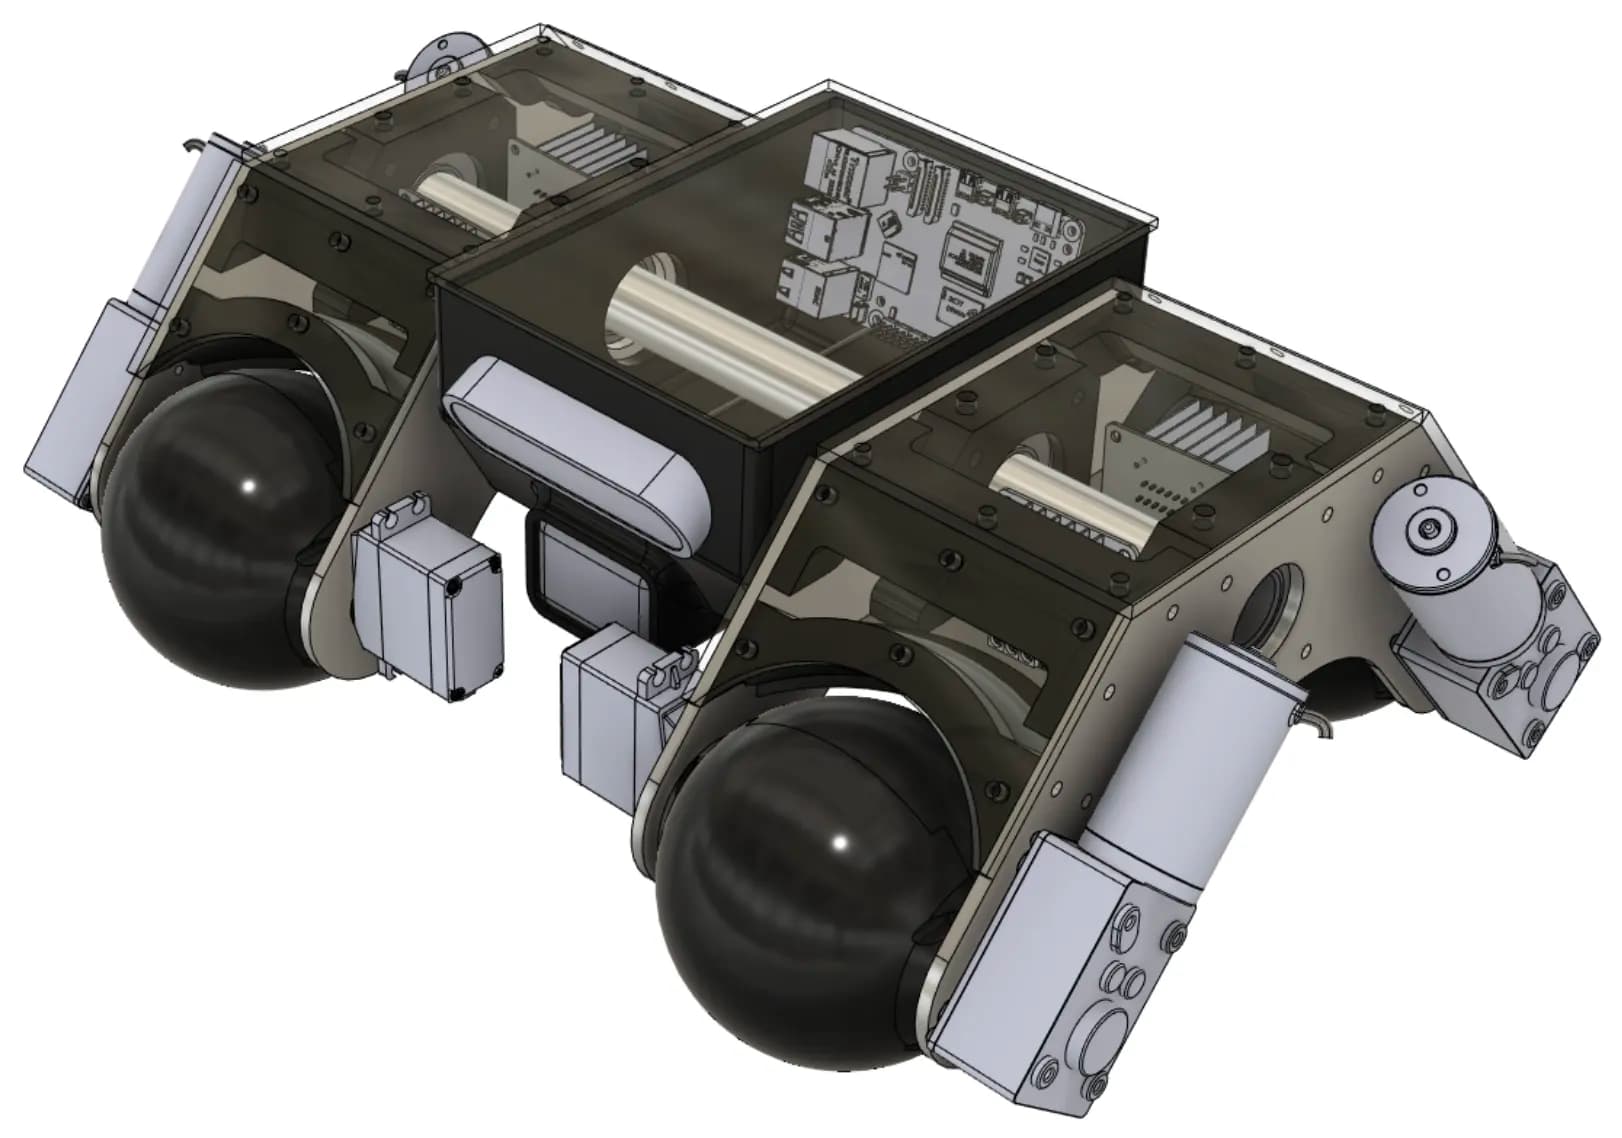
We developed a magnetic-adhesion robot that inspects vertical metal surfaces. As it moves across a surface, the robot builds a defect map in real time.
Maintaining stable adhesion on vertical surfaces of varying roughness and integrating a CV system with limited onboard computing resources.
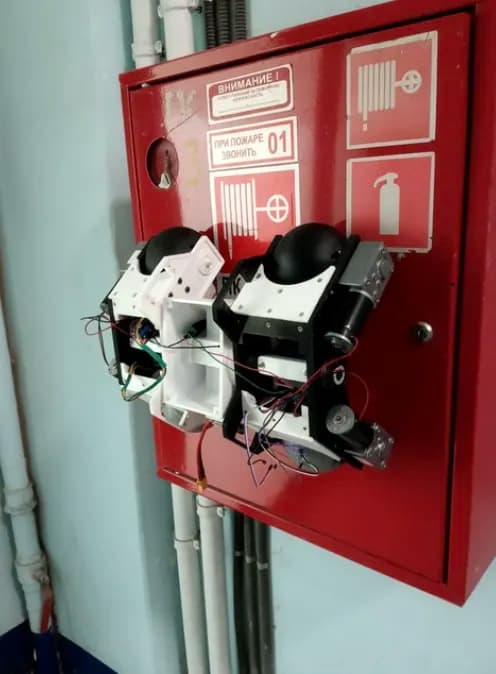
What sets the solution apart is that it collects defect analytics in places that are hard for people to reach. The robot analyzes fault data, classifies defects, and sends the results to the company’s server. The solution also includes additional plugins for extracting sensitive information, which are under NDA.
- 0101
Systems analysis
Gathering client requirements and researching best practices.
- 0202
Work plan approval
Agreeing on the robot design with the plant’s process engineers and analysts.
- 0303
Mechanical design
CAD modeling of the chassis, magnetic modules, and drivetrain.
- 0404
Control system
Drive controllers, surface locomotion algorithms.
- 0505
Computer vision
Training defect detection models, camera integration.
- 0606
Testing
Trials on test surfaces, calibration.
- 01ROS
- 02Python
- 03OpenCV
- 04STM32
- 05Embedded C
- 06CAD
Have a similar challenge?
We’ll review it and estimate within 5 business days.